Hiwonder ROSPug is smart quadruped robot dog built upon Robot Operating System (ROS). It is equipped with 12 high-voltage strong-magnetic serial bus servos and integrates a range of high-performance components, including NVIDIA Jetson Nano controller, TOF Lidar, HD camera, IMU sensor, OLED display, and more. Featuring self-developed dynamic balancing kinematics algorithm, it can switch seamlessly between multiple gaits.
ROSPug supports Gazebo simulation, providing users with a valuable platform to learn and validate quadruped kinematics algorithms and path planning. Thanks to the robust computing power of its controller, ROSPug can perform tasks such as SLAM mapping navigation, path planning, dynamic obstacle avoidance, climbing, obstacle bypassing, and many other applications. We also offer solutions for expansion of ROSPug's capabilities, including deep learning, machine vision, and other development projects to meet users' specific needs.
12 DOF Aluminium Alloy Structure
Hiwonder ROSPug employs 12 high-performance servos, distributed across its elbow, shoulder, and hip joints of each leg, closely mimicking the post of a real quadruped animal. Its entire body is crafted from aluminum alloy, with the calf joint reinforced by metal bearings, ensuring both low weight and high strength.
High-performance Hardware
ROSPug AI robot dog is powered by Jetson Nano and features high-performance Lidar and an HD wide-angle camera, enabling the validation of various creative AI applications.
Link Structure Enhanced Joint Efficiency
Hiwonder ROSPug features a link structure design that enhances the speed of the calf joint and ensures smooth motion without interference, thereby extending the leg's rotation range.
High-performance Intelligent Bus Servo
ROSPug features high-performance intelligent serial bus servos with a torque of 30KG, providing exceptional accuracy, data feedback, easy wiring, and support for a robust 12V voltage power supply.
Dual-Controller Design for Efficient Collaboration
ROSPug features a dual-controller design that combines the advanced AI capabilities of the Jetson Nano with the high-frequency control functions of the MCU. This integration enhances operational accuracy, enabling the system to tackle more complex challenges and explore a wider range of possibilities.
Function List
PC Software Control
Using graphical PC software, you can effortlessly control servos and customize actions by simply dragging sliders, without the need for programming.
Support Python Programming
All intelligent Python code is open source, with detailed annotations for easy self-study.
Coordinate PC Software Control
To support users in exploring ROSPug's capabilities, we offer detailed quadruped kinematics analysis, ROS-based inverse kinematics functions, and parameter debugging software.
APP Control
Android and iOS mobile APP are available. Via the APP, you can remotely control the robot and view what the robot sees.
Line Following
ROSPug can recognize red lines, and then calculate the location of the line so as to adjust the walking gait and realize line following.
Drifting in Circle
By utilizing visual recognition to identify the circular pile and measuring the distance between itself and the pile using Lidar, the robot can adjust its moving direction to perform circular drifting.
Up and Down Stairs
Through independent vision judgment, the position of the stairs in front is identified and the scene of autonomously going up and down the stairs is realized.
Ball Shooting
ROSPug utilizes OpenCV to determine ball's position and employs a PID algorithm for real-time ball tracking. This approach allows it to fine-tune its gait to achieve accurate ball shooting, considering the distance from the target and the target's location.
ROS Robot Operating System
Global Popular Robotic Communication Framework
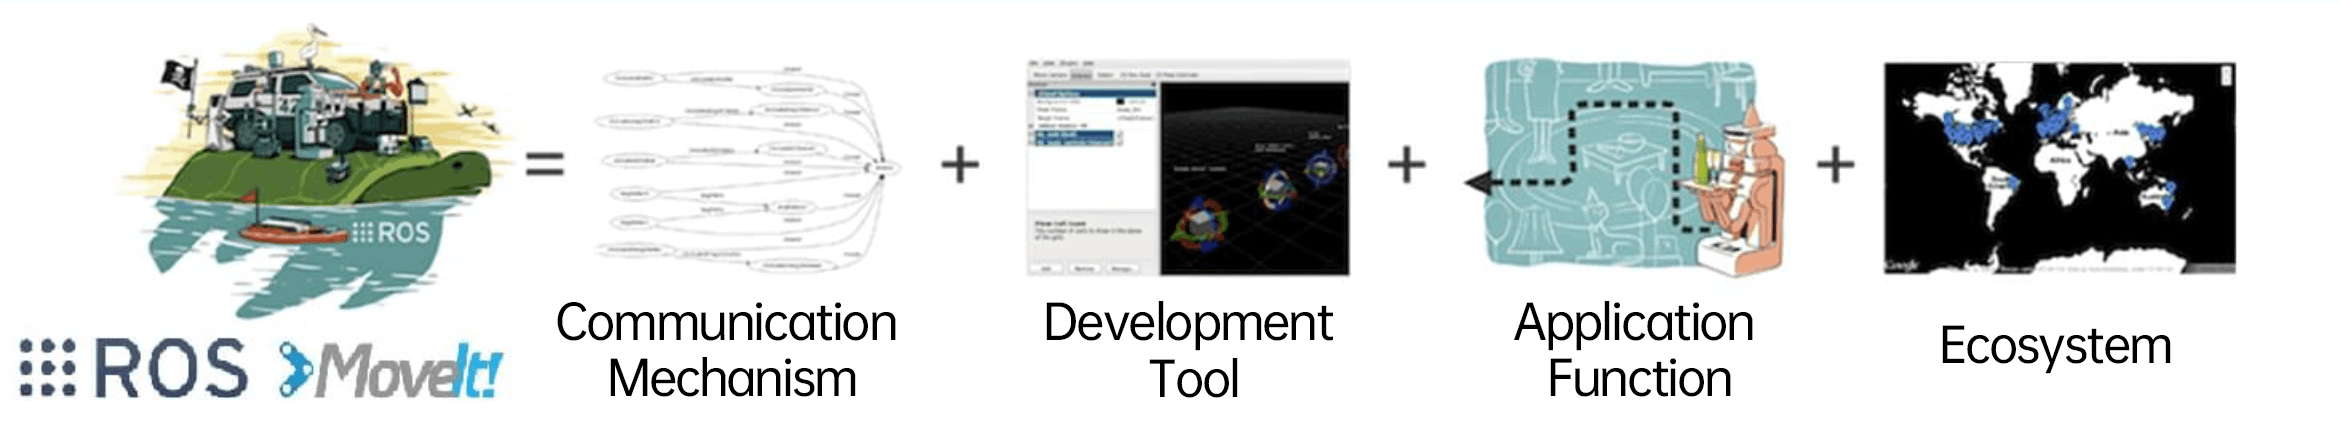
ROS is an open-source meta operating system for robots. It provides some basic services, such as hardware abstraction, low-level device control, implementation of commonly used functionality, message-passing between processes, and package management. And it also offers the tools and library functions needed to obtain, compile, write, and run code across computers. It aims at providing code reuse support for robotics research and development.
Gazebo Simulation
ROSPug utilizes the ROS framework and offers Gazebo simulation support. Gazebo provides a novel approach for controlling ROSPug and validating algorithms within a simulated environment, reducing the need for physical experiments and enhancing efficiency.
Product Structure
Size
334*211*210 mm
Main controller
Jetson Nano
Torque of joints
30KG.cm 12V
Material
Aluminum alloy structure + rubber (foot pad)
DOF
12DOF
Weight
About 1.65KG
Camera pixel
8 megapixel
Power
11.1V 3500mAh 5C LiPo battery
App
WonderROS (Android/iOS)
Built-in host
Jetson Nano
GPU
NVIDIA Maxwell architecture, equipped with 128 NVIDIA CUDA cores
CPU
Quad-core ARM Cortex-A57 MPCore processor
Memory
4GB 64-bit LPDDR4
Storage
64GB SD card
Package size
44.5*33*18cm
Package weight
3.1kg
Product Parameters
Dimensional Diagram
ROSPug Packing List
Hiwonder ROSPug Quadruped Bionic Robot Dog
Default Title
Robot Pi Shop
Pickup available,usually ready in 1 hour
Ground Floor Shop, Sayde Street, Fanar Matn 1202 Fanar Lebanon